Software
Profiles
- GitHub: @jlblancoc
- Packages: Debian/Ubuntu Developer Profile
Online Engineering Tools
Tensora.app: structural analysis in your browser
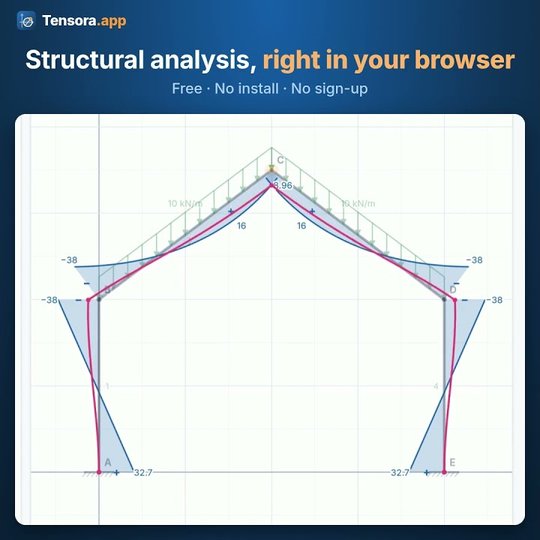
Tensora.app is a free web application for structural analysis and mechanics of materials, for students and engineers in civil, mechanical and industrial engineering. Define nodes, beams, loads and supports, and it solves 2D beams, trusses and frames with the finite element method and draws the axial force, shear force and bending moment diagrams and the deflected shape as you edit the model. It runs entirely in the browser, with no installation or sign-up: its solver is my C++ structural analysis library, OpenBeam, compiled to WebAssembly.
- Structural analysis: beams, continuous beams, trusses and frames, with a gallery of classic cases (cantilevers, fixed-fixed beams, Warren truss, portal and three-hinged frames) ready to modify and solve.
- Mohr's circle: interactive 2D Mohr circle of a plane stress state, with shareable links and PNG export.
- 3D stress tensor: traction vectors on the sphere of normals, principal stresses and directions, and the three Mohr circles.
- Languages: English, Spanish, French and Chinese.
- Website: tensora.app
Core Robotics Frameworks
MOLA: Modular Optimization and Localization Abstraction
The successor to the SLAM foundations of MRPT, MOLA is a modular, high-performance C++ framework designed for lifelong SLAM, localization, and mapping. It is built to be highly extensible through a plugin-based architecture, and includes a state-of-the-art LiDAR odometry and the mp2p_icp point cloud registration library.
- Status: Active / Most Relevant
- Documentation: docs.mola-slam.org
- Repository: github.com/MOLAorg
MRPT: Mobile Robot Programming Toolkit

A mature, cross-platform C++ library (2005-present) providing developers with a vast collection of algorithms for robotics: SLAM, computer vision, and motion planning.
- Highlights: Extensive support for 2D/3D range sensors, probabilistic motion models, and real-time visualization.
- Website: www.mrpt.org
- Repository: github.com/MRPT
MVSim: Multi-Vehicle Simulator
A lightweight, realistic 2.5D dynamics simulator for wheeled robots and multi-agent research, with simulated LiDARs, cameras and other sensors. Worlds are fully configured via XML files, and it runs standalone, as a ROS 2 node, or embedded in C++/Python applications, including a headless mode for CI pipelines.
- Documentation: mvsimulator.readthedocs.io
- Repository: github.com/MRPT/mvsim
nanoflann
A header-only C++ library for building KD-trees and running fast nearest neighbor searches on point clouds and other datasets, widely used in robotics, computer graphics, and machine learning.
- Repository: github.com/jlblancoc/nanoflann
ROS Ecosystem

I maintain a wide variety of ROS 2 integrations to bridge high-performance C++ backends with the ROS middleware.
- MRPT ROS Packages: The official bridge between MRPT and ROS 2, including
mrpt_navigation,mrpt_slamandmrpt_sensors. - MOLA and MVSim: Both are available as binary ROS 2 packages.
- UAL ARM ROS: Packages specifically for robotic arm control and integration.
- GitHub Orgs: github.com/mrpt-ros-pkg | github.com/ual-arm-ros-pkg
Specialized Engineering Organizations
Multibody Dynamics & Simulation (MBDS)
Tools and libraries focused on the simulation of complex mechanical systems and multibody dynamics.
- Repository: github.com/MBDS
LibreDAQ: Open Data Acquisition
A collection of projects dedicated to open-source hardware and software interfaces for data acquisition.
- Repository: github.com/LibreDAQ
Mechanical Design & Structural Analysis

- Open-Beam: Specialized tools for structural and beam analysis. (github.com/open-beam). Its C++ solver powers Tensora.app, the online structural analysis tool.
- Mechplot: A MATLAB library for rendering structures and mechanisms. (github.com/jlblancoc/mechplot)
Developer Tools & Utilities
- SuiteSparse-METIS for Windows: A CMake-based build system that enables the use of these powerful sparse matrix libraries in Visual Studio and other CMake-supported IDEs.
- RWL (Recursive World Language): A domain-specific language and interpreter for generating vast simulated worlds for SLAM benchmarking.
- Eigen: Proud (though minor) contributor to this world-class C++ template library for linear algebra.
Didactic & Historical Projects
- A tutorial on SE(3) transformation parameterizations and on-manifold optimization: Technical report on Lie groups for 3D pose estimation, with its LaTeX sources.
- Robotics teaching notebooks: Jupyter notebooks used in Robotics courses at UAL.
- Mohr 2D GUI: Visualizes a 2D stress tensor and its Mohr's circle.
- Maxwell-Boltzmann Simulator: A graphical simulator illustrating the kinetic theory of gases and probability distributions.
- Denavit-Hartenberg GUI: A visual tool for learning and teaching robotic arm kinematics, distributed with MRPT.
- OpenMORA (2008-2014): A middleware framework based on MOOS and MRPT. This was before ROS took off.
- Open-CV Bots: Experimental computer vision programs designed to autonomously play web-based games.
- Syncpath: A lightweight, cross-platform CLI tool for directory synchronization and backups.